The original concept for this machine comes from a design of a “muscle” from the game poly bridge, which a game about building bridges. Here is what steel/wooden muscles look like:
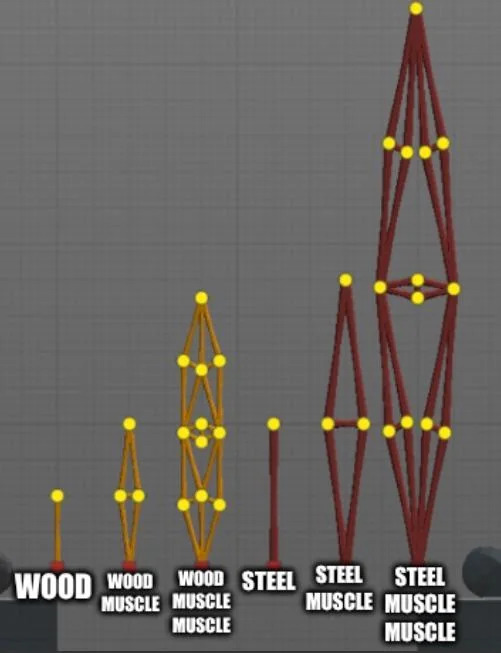
This inspiration comes from how those wood/steel segments remind me of linkages. The game also has a mechanical part with hydraulics that I could have used as a reference as well because I think it’s relevant since we are using servos.
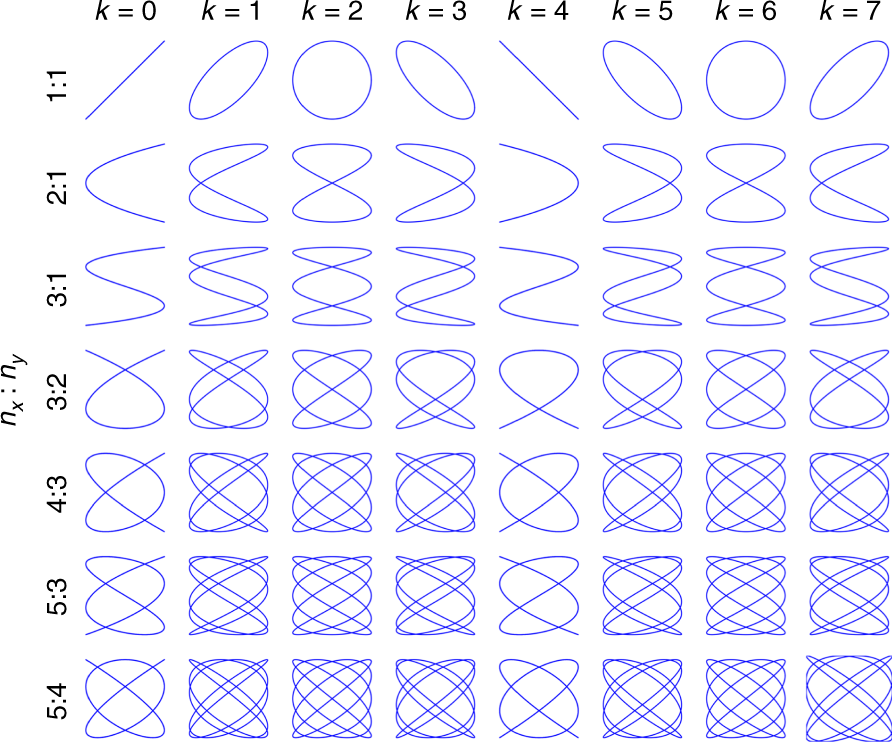
I also am inspired by Lissajous patterns, Lissajous patterns are elegant mathematical patterns formed when two oscillating motions act at right angles to each other.
Before trying to implement something similar, I prototyped with random linkages and random anchors here and there.
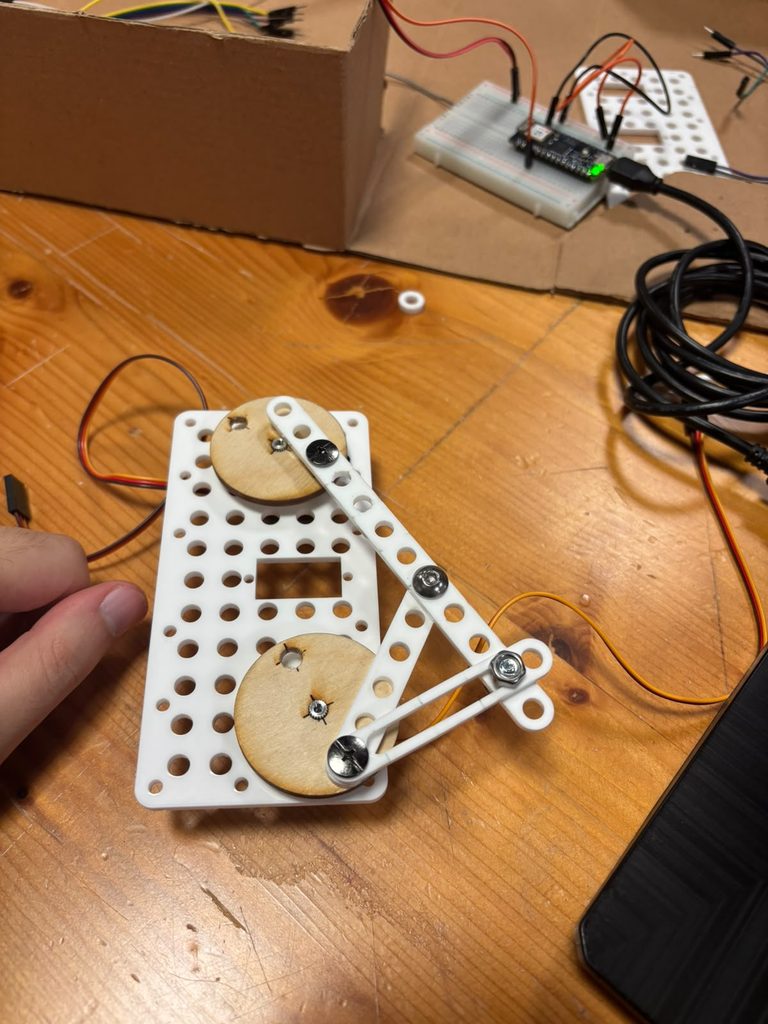
This allowed me to understand how each link could influence and limit the other. I think I found this assignment particularly difficult because it was supposed to be a group assignment and due to circumstances with my teammate I had to do it alone. I ran into a couple of issues like fitting the horns on the servo and the chicago screws on the horns which I realized then I have to use a mallet to push them in slightly.
I then implemented the linkage system in my mind and moved it manually with my hands before writing code to see how things would turn out. Also before this step, I marked each starting and ending point of the servos to understand their range of motion from 0-180 to know what to expect movemenet wise before I start moving the linkages with code.
I then took inspiration from the sweep code and offset the servos a little bit but you can see that the movement s pretty limited and I couldn’t really figure out how to change the linkages in a way that keeps the original idea but also draw better results and not get stuck
This design produced these results in blue.
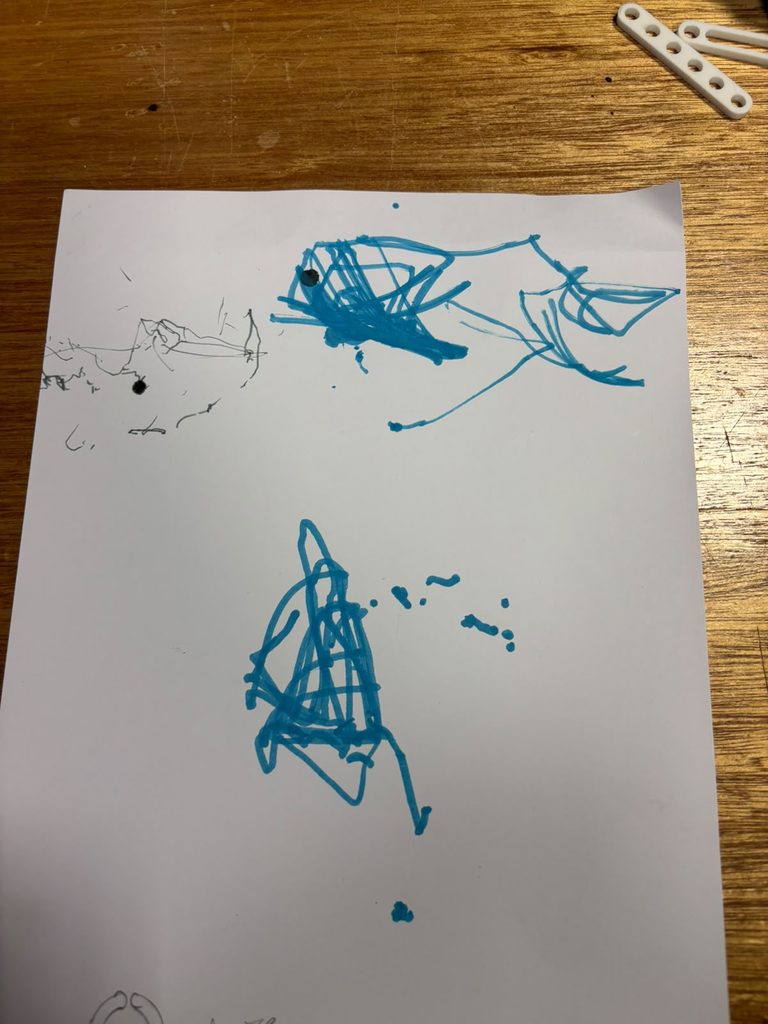
I realized that the anchor would start moving after a bit and the design isn’t really looking how I want it to look, so I experimented with a different design using slotted parts as professor jack instructed during office hours and instead of using a sharpie I used a finer pen. Moreover, the system wasn’t very stable so I drilled into a wooden board and I screwed the project on it using m5 bolts and nuts.
Here’s the final design
Here are some drawing outputs, each block of drawing is a different iteration.
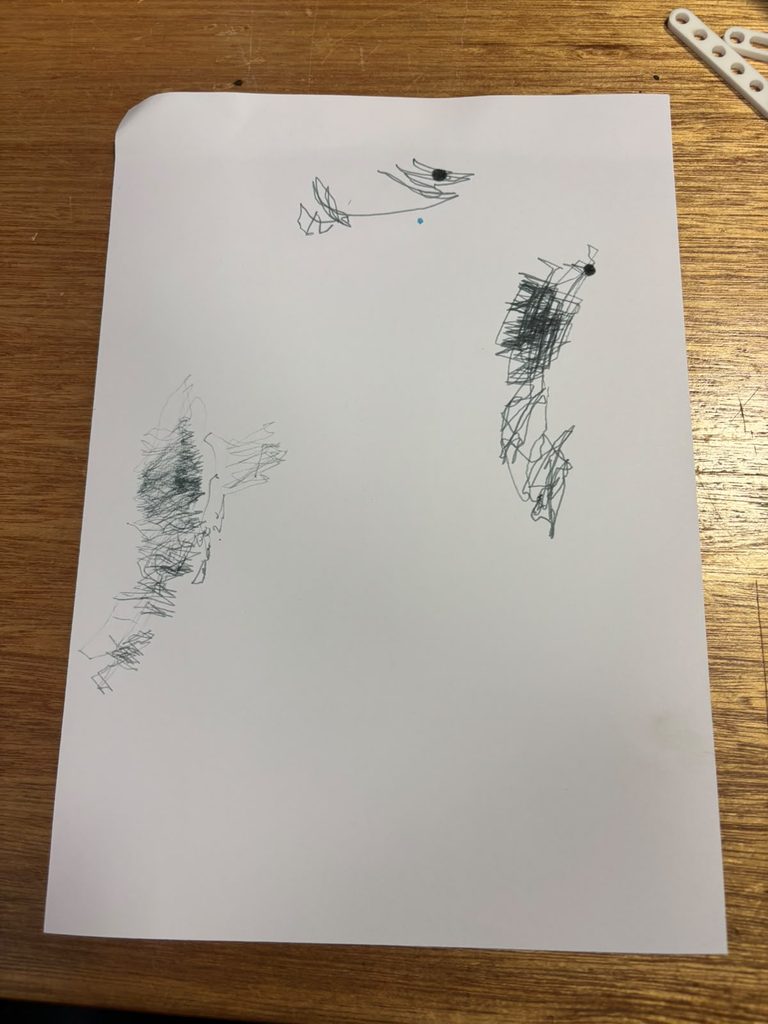
Honestly I am not too happy with this how turned out as I couldn’t create something that slightly resembles Lissajous patterns but I definitely learned a lot. Hopefully later on if we revisit the assignment in a different form I would definitely be more prepared for it. Overall though I think this class really pushes you to learn something different and new and I believe it should be a 3000 level course.
I think changing the drawing instrument here really affected how the result looks, i think a finer pen worked really well in demonstrating the robotic movements of this system. Also, switching from normal linkages to slotted ones added a very fast shift every now and then that added a lot of life and scale to the drawing.